Model predictive control laws learned as oblique decision trees, over 1,000× faster than online MPC.
Overview
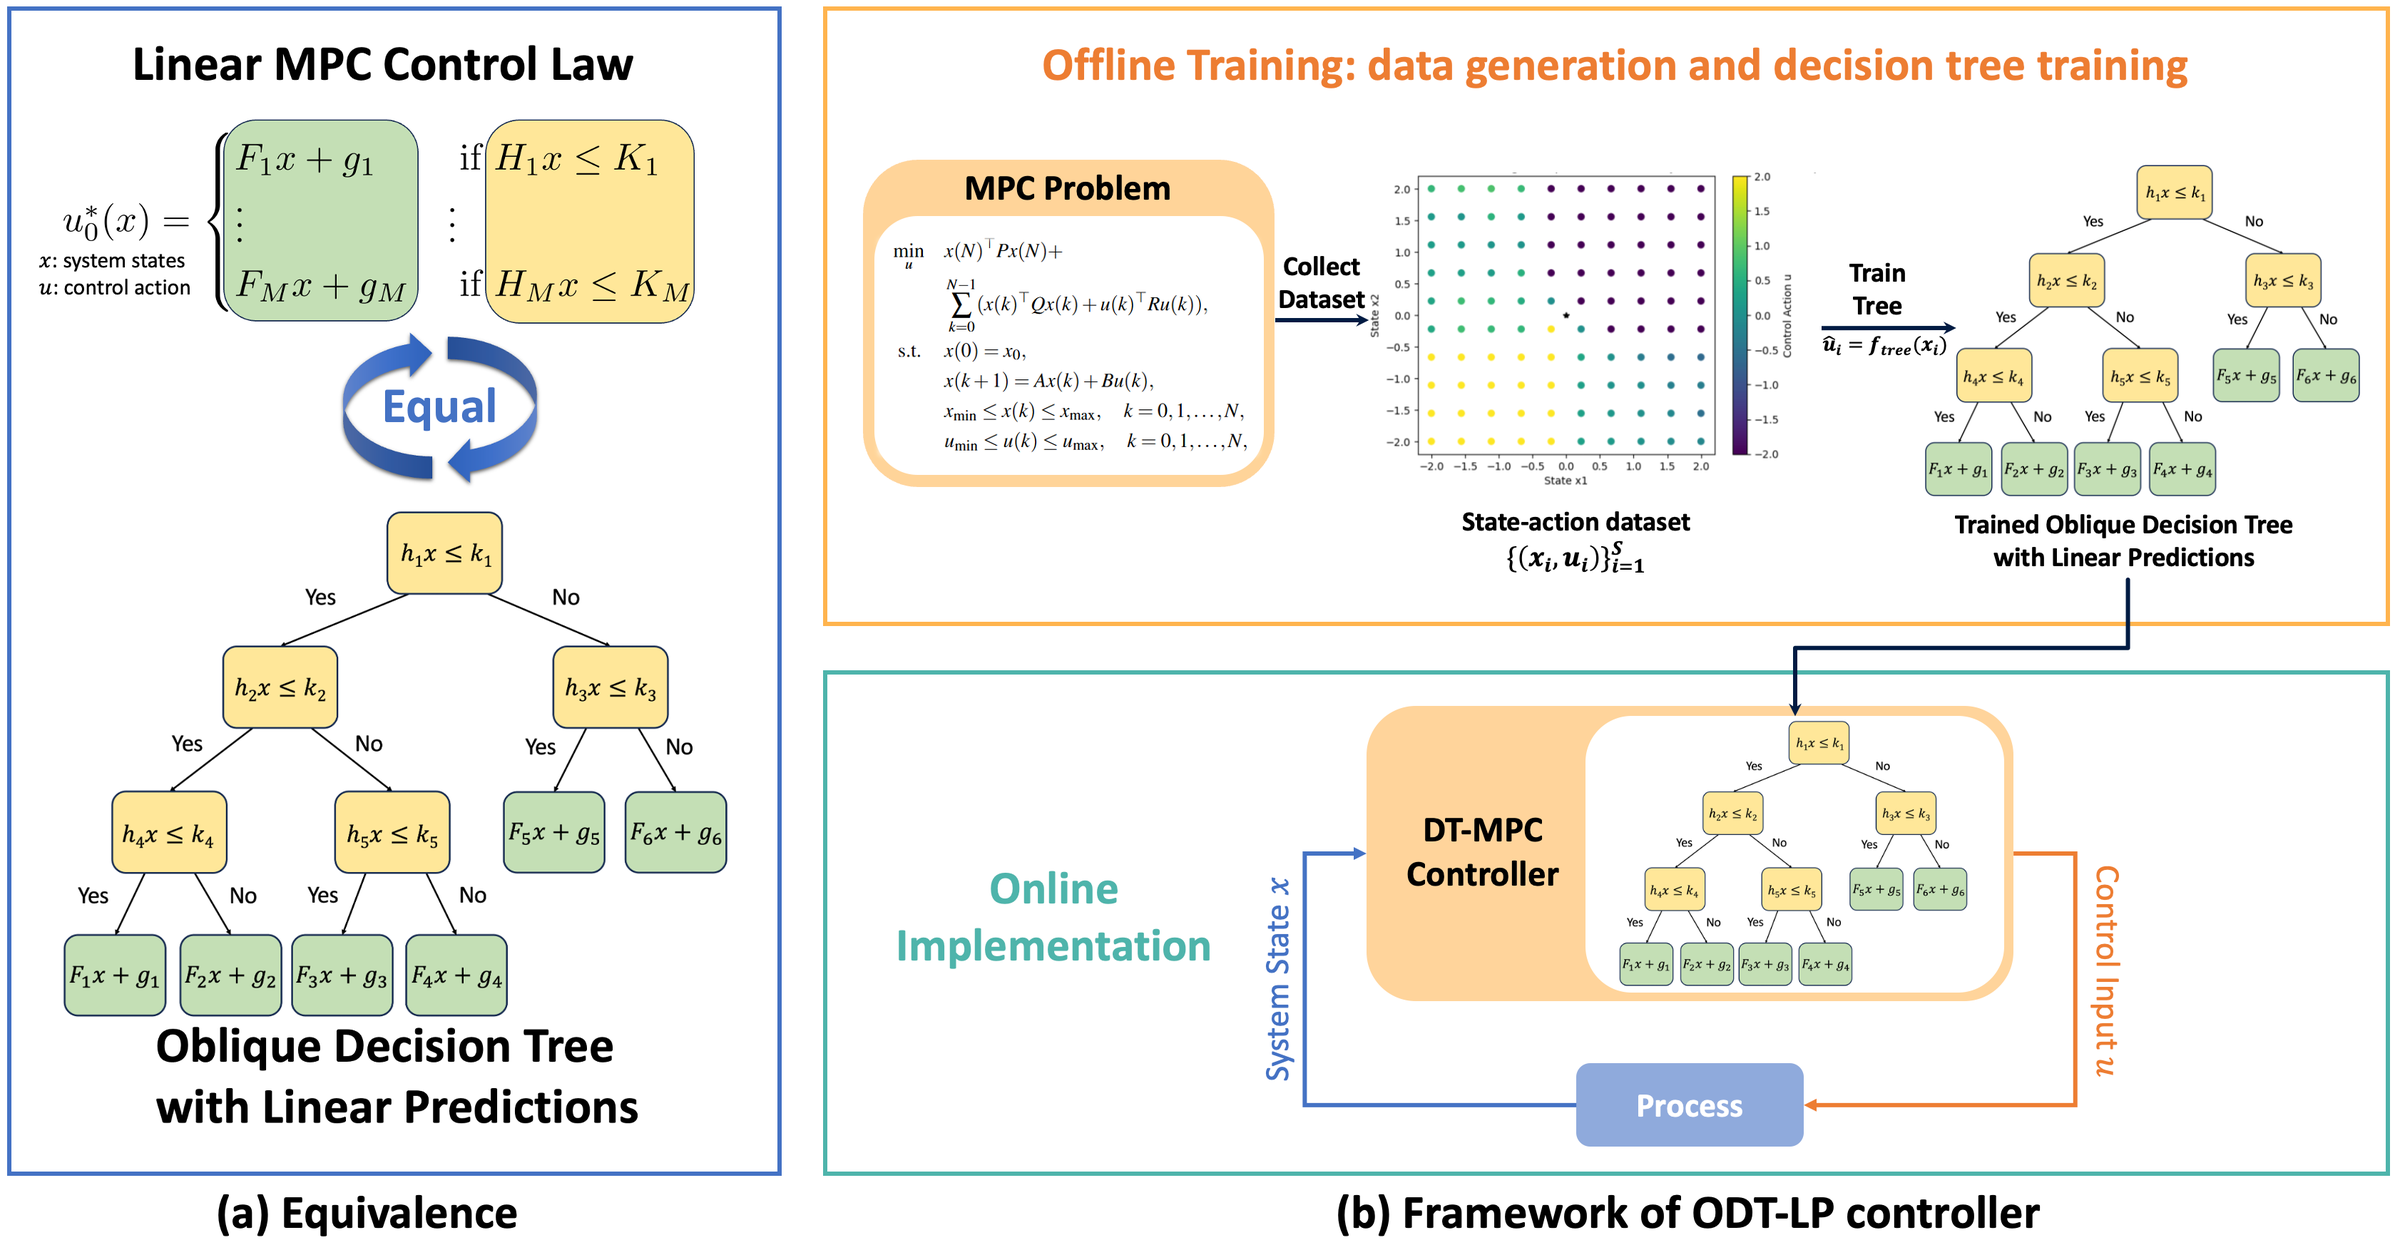
Model predictive control (MPC) performs well but must solve an optimization problem online at every step. The control law of linear MPC is piecewise affine, so it can be represented exactly by an oblique decision tree with linear predictions at the leaf nodes. Building on this, I learn MPC laws as interpretable decision trees offline and deploy the tree online as the controller.
Results
The resulting controllers perform competitively with MPC at the speed of a low-level PID controller: over 1,000× faster than MPC and 10× faster than neural network equivalents. I have extended this framework to quadcopter control and to interpretable reinforcement learning for multi-loop adaptive PID control.
Publications
Exact Learning of Linear Model Predictive Control Laws Using Oblique Decision Trees with Linear Predictions
64th IEEE Conference on Decision and Control, pp. 7018–7023 (2025).
Fast, High-Performance, and Interpretable Quadcopter Control Using Decision Trees
23rd IFAC World Congress (2026).
Interpretable Reinforcement Learning for Multi-Loop Adaptive PID Control
23rd IFAC World Congress (2026).
Deep Learning-Based Approximation of Model Predictive Control Laws Using Mixture Networks
IEEE Transactions on Automation Science and Engineering, 22: 2909–2922 (2024).
Hierarchical Model Predictive Control for Energy Consumption Regulation of Industrial-Scale Circulation Counter-Flow Paddy Drying Process
Energy, 321: 135431 (2025).
* Co-first authors